Mining Technology
Subterranean Autonomous Mining Drones Utilize SLAM and Radar to Map Unstable Underground Tunnels
Mining engineering firms have successfully deployed ruggedized autonomous drones equipped with simultaneous localization and mapping (SLAM) and ground-penetrating radar to inspect unstable subsurface tunnels.
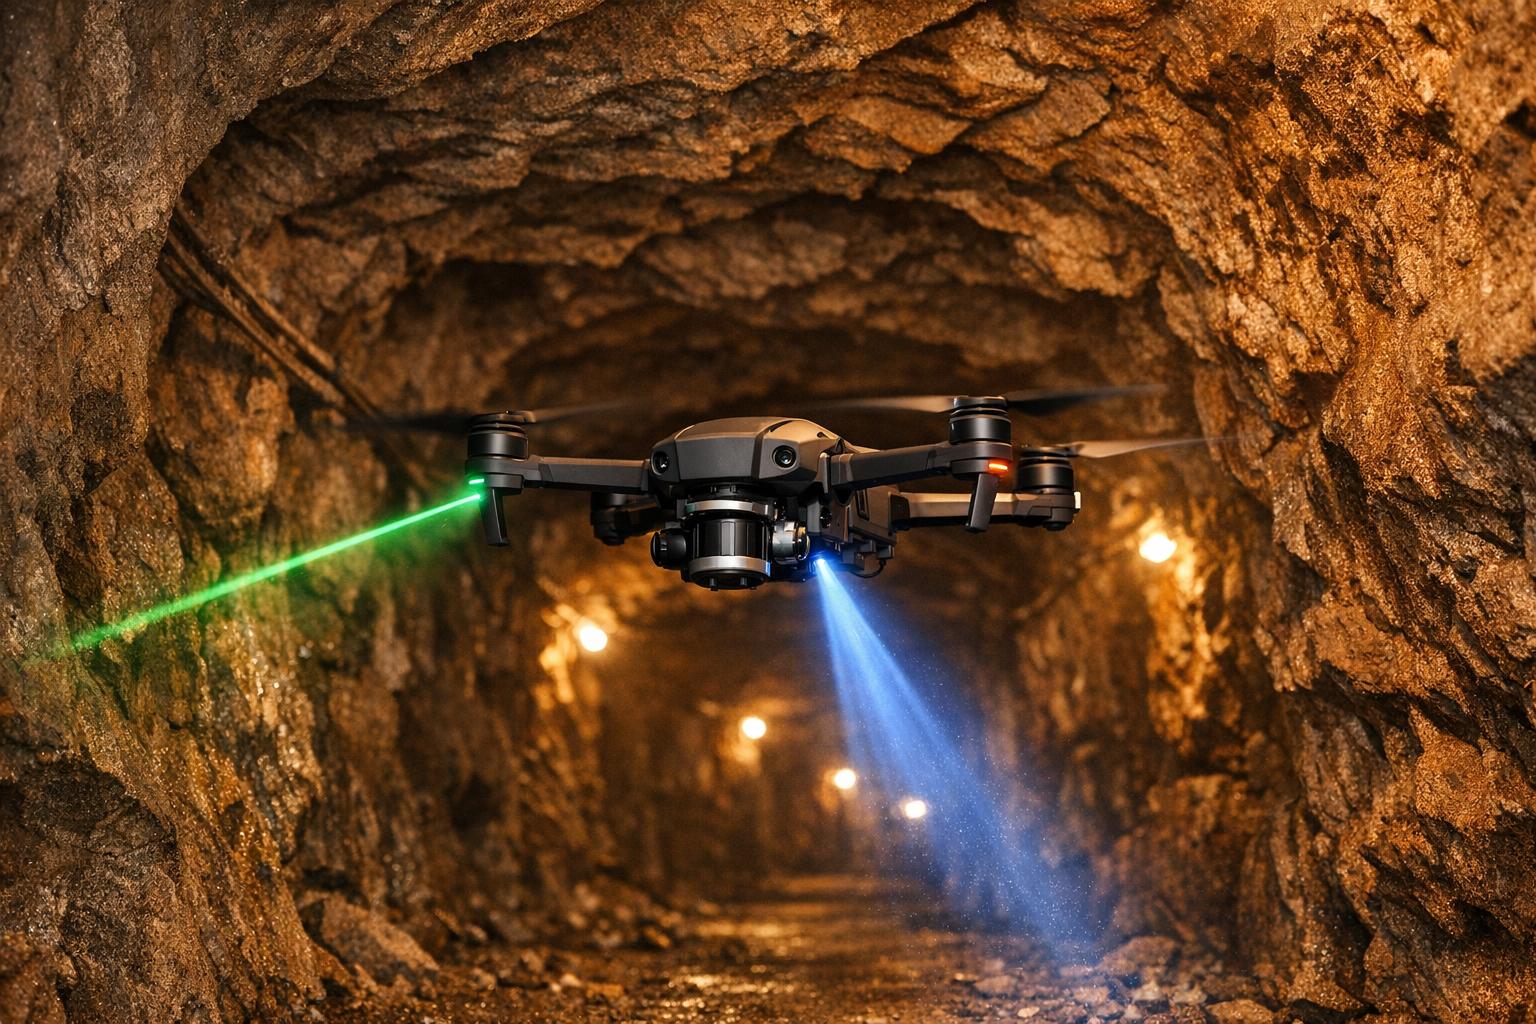
Inspecting deep underground mining tunnels and abandoned subterranean shafts presents extreme hazards for human inspection teams, who face constant risks from rockfalls, toxic gas pockets, and structural instability. Conventional GPS navigation is entirely unavailable underground, forcing robotic systems to rely entirely on onboard perception and mapping technologies. Addressing these severe operational constraints, SubTerra Robotics has introduced a ruggedized, cage-protected autonomous drone designed specifically for GPS-denied subterranean exploration and structural mapping.
The core technological innovation enabling autonomous flight in pitch-dark, confined underground environments is advanced Simultaneous Localization and Mapping (SLAM) software running on an ultra-compact edge processor. As the drone navigates through narrow mining stopes and exploratory tunnels, its onboard 3D LiDAR scanner and stereo infrared cameras map the surrounding rock geometry at thousands of points per second, constructing a highly accurate 3D spatial model in real time without external positioning signals.
Equipped with a robust spherical carbon-fiber protective collision cage, the drone is engineered to withstand direct impacts against uneven rock walls, protruding timber supports, and fallen debris without losing stability or damaging vital rotor assemblies. If physical contact occurs during narrow passage navigation, internal damping mounts absorb the shock while the flight controller instantly re-establishes stable attitude control.
In addition to optical and LiDAR mapping payloads, the subterranean drones carry specialized ground-penetrating radar (GPR) and gas-sensing sensor packages. As the aircraft cruises slowly along tunnel walls, the GPR system pulses high-frequency electromagnetic waves into the surrounding rock strata, detecting hidden fractures, void spaces, and unbolted structural weaknesses behind the concrete or mesh lining before catastrophic collapses occur. Simultaneously, electrochemical gas sensors monitor ambient levels of methane, carbon monoxide, and oxygen, transmitting real-time safety telemetry to surface control operators.
Mining engineering teams utilizing the subterranean inspection platform report dramatic improvements in mine safety and operational efficiency. By dispatching autonomous drones into newly blasted stopes or unstable historical workings, mining companies eliminate the need to expose human surveyors to high-risk environments while gathering comprehensive structural data that informs ground support reinforcement strategies.
As deep-level mining operations push deeper underground and face stricter safety regulations, autonomous subterranean drones are becoming an indispensable asset for modern resource extraction. SubTerra Robotics is currently expanding its deployment across underground mineral mines worldwide, establishing new benchmarks for remote hazard detection and underground asset integrity management.
The broader implications for the mining technology sector extend well beyond the immediate technical achievement. Industry analysts note that this deployment represents a convergence of several previously separate technological streams — advanced materials science, edge computing, and autonomous flight control — into a single integrated platform. The fact that these systems can now operate reliably in real-world conditions, rather than only in controlled test environments, signals a maturation of the unmanned aviation industry that has been anticipated for over a decade.
Safety certification and regulatory compliance remain among the most significant hurdles for widespread adoption. Aviation authorities worldwide have been working to establish clear operational frameworks that balance innovation with public safety. The platform described here has undergone extensive testing under various regulatory regimes, including controlled airspace trials, risk assessment evaluations, and operational safety case reviews. These regulatory milestones are as important as the technical specifications, because they determine whether a technology can transition from experimental novelty to routine commercial deployment.
The economic case for this technology becomes more compelling when examined over extended operational timelines. While initial acquisition costs may exceed those of traditional methods, the cumulative savings from reduced labor requirements, decreased downtime, and prevention of catastrophic failures create a compelling return on investment. Organizations that have integrated these systems into their standard operational workflows report that the total cost of ownership over a three-year period is significantly lower than maintaining equivalent conventional capabilities, particularly when factoring in the avoided costs of accidents, delays, and environmental damage.
Looking ahead, the development roadmap for this platform includes several enhancements that could further expand its operational utility. Engineers are exploring integration with complementary sensor technologies, improved machine learning models for real-time decision making, and enhanced communication protocols that would allow seamless coordination with other autonomous systems. The vision is not simply a better individual aircraft, but a connected ecosystem of unmanned platforms that can share data, coordinate missions, and collectively adapt to changing environmental conditions without human intervention.
Environmental considerations play an increasingly central role in the design and deployment of unmanned aerial systems. The shift away from fossil-fuel-dependent manned aircraft toward electric and hydrogen-powered drones represents a meaningful reduction in carbon emissions per mission. Additionally, the reduced acoustic footprint of these platforms minimizes disturbance to wildlife populations in sensitive ecological zones, an important factor for operations near protected habitats and marine reserves. The sustainability benefits extend to reduced ground vehicle deployments, as drone-based inspections eliminate the need for trucks and heavy equipment to access remote inspection sites.
Training and workforce development represent another critical dimension of this technological transition. Operating and maintaining these advanced systems requires specialized skills that differ significantly from traditional aviation maintenance. Organizations deploying these platforms have invested substantially in training programs, certification curricula, and simulation-based learning environments to ensure that their personnel can operate safely and effectively. The emergence of this new professional skill set reflects the broader transformation of the aviation workforce as unmanned systems become increasingly prevalent across commercial and industrial sectors.
Related briefings
More from
Mining Technology

Industrial Logistics
AeroHytech Deploys Hydrogen-Powered Heavy-Lift Cargo UAVs for Remote Alpine Infrastructure Supply
Breaking endurance barriers in extreme environments, AeroHytech has officially commercialized a hydrogen-fuel-cell heavy-lift drone capable of sustained multi-hour freight missions across high-altitude terrain.
Renewable Energy Inspection
Autonomous Offshore Wind Turbine Inspection Fleets Operationalize Edge AI and LiDAR Navigation
Maritime energy operators are now deploying fully autonomous drone fleets equipped with solid-state LiDAR and onboard neural processors to inspect offshore wind turbine blades without human pilot oversight.
Precision Agriculture
Precision Agritech Breakthrough: Hyperspectral Drone Swarms Enable Real-Time Crop Disease Mapping
Agricultural researchers have successfully deployed synchronized drone swarms utilizing hyperspectral imaging and machine learning to detect crop pathogens days before visible symptoms emerge in the field.